Home / Knowledge Hub / Designing for Consistent Capture

How to Design for Consistent Particle Capture

Five Things to Consider

A magnetic debris sensor does not have a single capture efficiency. The installation sets it. In our models, the same sensor caught anywhere from under 1% to over 90% of the passing steel chips, depending on the fluid temperature, where the sensor sat, how fast the fluid moved past it and how the flow met the sensing face. For a debris monitor, the best case is not the number that matters. What matters is how much capture changes across the operating envelope, because a debris trend is only as reliable as the fraction of debris the sensor sees.

What Moves Capture

We ran two sets of models. A pipe model tracked steel chips through a 0.75 in line of MIL-PRF-23699 turbine oil past an NZMS sensor, sweeping fluid temperature, velocity, sensor position and the position of the sensing face one at a time. A three-dimensional flow solver then ran 23 cases on five test passages, also 0.75 in, to check the trends in real geometry, to compare different ways of bringing the flow to the sensor and to add the pressure loss. The chart below ranks each variable by how far it moved capture over a practical range, for small (50 µm) and large (400 µm) chips.

Ranked bar chart of the swing in capture efficiency for 50 and 400 micron chips: fluid temperature 58 and 89 points, sensor position 3 and 65, velocity at the sensor 58 and 46, tip into the flow 34 and 19, flow aimed at the face 18 and 2, debris steel grade under 1 for both
The swing in capture each variable gives, for small and large chips. Fluid temperature moves capture the most for both. After it, velocity matters most for small chips and sensor position for large chips. The debris steel grade, shown for scale, does almost nothing. The bars do not add up, because each effect depends on where the others are set.

Small and large chips respond to different things. Small chips follow the flow, so whatever brings fluid close to the face, or slows it there, helps them. Large chips are heavy enough to settle, so gravity and the sensor's position decide whether they ever arrive. The five sections below cover the choices a designer controls. The debris itself is not one of them, and it turns out not to matter much, as the last section shows.

1. Design to the Cold Case

The magnet pulls a chip sideways across the flow while the fluid drags against it. The chip's sideways speed is set by that drag, so it is inversely proportional to the fluid's viscosity. Viscosity is therefore the strongest single influence on small-chip capture, and in most systems viscosity is set by temperature. The designer cannot choose the temperature, but can choose which temperature the installation is designed for.

Line charts of capture efficiency against fluid temperature for MIL-PRF-23699 turbine oil and Jet A at 50, 150 and 400 microns. In 23699, 50 micron capture rises from almost 0 at minus 40 F to 58 percent at 300 F. In Jet A it rises from 41 to 88 percent.
Capture against fluid temperature for MIL-PRF-23699 turbine oil and Jet A fuel. Cold turbine oil lets most chips under 150 µm pass. Jet A changes viscosity far less, so its capture is much more consistent across temperature.

MIL-PRF-23699 thickens from 2.4 cSt at 300°F to about 12,000 cSt at −40°F. Across that range, capture of 50 µm chips falls from 58% to almost zero, and capture of 150 µm chips falls from 93% at 245°F to 1.5%. Even at 32°F, the sensor catches only 8% of 50 µm chips and 29% of 150 µm chips. Debris shed during a cold start passes the sensor. Jet A covers a much narrower viscosity range, and its small-chip capture stays between 41% and 88%. Large chips behave differently at the hot end. Above about 150°F their capture falls again, because in thin oil they settle to the pipe wall before they reach a sensor on the side. The same physics applies to hydraulic fluids, whose viscosity also falls steeply as they warm.

Design action. Define the lowest fluid temperature at which detection is required and evaluate capture there, not at the nominal condition. Where the monitor trends debris over time, compare readings taken at similar fluid temperatures, or correct for temperature. A change in the debris rate is only meaningful if the capture fraction behind it has not changed.

The cold case sets the minimum capture. A trend built across a wide temperature range mixes changes in wear with changes in viscosity.

2. Mount the Sensor Low

Large chips settle out of a slow horizontal flow. Whether they reach the sensor depends mainly on where the sensor is.

Grouped bar chart of capture by sensor position. Top: 18, 32 and 8 percent for 50, 150 and 400 microns. Side: 20, 48 and 64 percent. Bottom: 22, 62 and 73 percent.
Capture by sensor position around a horizontal 0.75 in passage, diesel at 68°F, 1.1 ft/s. Small-chip capture hardly changes. A sensor on top loses almost all of the 400 µm chips.

For 50 µm chips, moving the sensor from the top of the line to the bottom changed capture by only 3 points. For 400 µm chips, it changed capture from 8% to 73%. A swirl chamber with the sensor in its floor caught 81% of the 400 µm chips. The same chamber mounted upside down, with the sensor in its roof, caught none. Large chips are the ones that signal advanced damage, so a sensor that cannot see them misses the most important debris.

Design action. Mount the sensor on the bottom of a horizontal line, or in the floor of a chamber, and place it close downstream of where debris enters the flow. Avoid long, slow horizontal runs between the debris source and the sensor, where large chips can settle before they arrive.

3. Size the Cavity for the Right Velocity

The system sets the flow rate. The designer sets the velocity at the sensor, by choosing the bore or cavity it sits in. Mean velocity is the flow rate divided by the flow area, so it falls with the square of the diameter. A cavity 1.4 times the line diameter halves the velocity at the sensor.

Slower flow gives the magnet more time to act on each chip. That helps small chips steadily. For large chips there is a limit, because flow that is too slow lets them settle before they reach the sensor.

Two line charts of capture efficiency against mean velocity on a log scale. Left, MIL-PRF-23699 at 245 F: 50 micron capture falls from 71 percent at 0.07 ft/s to 14 percent at 1.5 ft/s, and 400 micron capture peaks at 94 percent at 0.73 ft/s. Right, diesel with the sensor on the bottom: 400 micron capture rises from 0.5 percent at 0.36 ft/s to 92 percent at 2.2 ft/s.
Capture against the mean velocity at the sensor. Small-chip capture falls steadily with velocity. Large-chip capture has a best velocity, below which chips settle before they arrive.

In MIL-PRF-23699 at 245°F, capture of 50 µm chips fell from 71% at 0.07 ft/s to 14% at 1.5 ft/s. Capture of 400 µm chips peaked at 94% near 0.73 ft/s and fell to 48% at 0.07 ft/s, where most of them settle before they reach the sensor. The best velocity also depends on how far the debris travels to the sensor and whether the flow can push settled chips along the floor. In the diesel passage with the sensor on the bottom, 400 µm capture was 0.5% at 0.36 ft/s, 73% at 1.1 ft/s and 92% at 2.2 ft/s. At the lowest velocity the large chips settled in the inlet and stayed there. The same velocity change cut 50 µm capture from 40% to 16%.

Design action. Size the bore or cavity at the sensor for the velocity, not just to match the line. Check both ends of the system's flow range: the velocity at minimum flow must still carry large chips to the sensor, and the velocity at maximum flow must still give the magnet time to catch small ones. Capture at idle and at maximum flow can differ by a factor of several.

4. Aim the Flow at the Sensing Face

The magnet reaches only a short distance into the flow. A chip is caught only if the flow brings it close to the face. There are two ways the direction of the flow can help. The first is simply delivery: a flow that runs straight at the face carries its chips into the magnet's reach. The second is inertia: a heavy chip cannot follow a sharp turn in the flow, so it is thrown outward, toward a sensor placed on the outside of the turn.

Which of the two matters depends on the Stokes number, the ratio of a chip's response time to the time the flow takes to turn. In the diesel passages at 1.1 ft/s, it is about 0.005 for a 50 µm steel chip, 0.04 at 150 µm and 0.3 at 400 µm. Small chips follow the flow almost exactly, so for them only delivery counts. Large chips partly follow the turn, and inertia starts to help. The Stokes number rises with velocity and with the square of the chip size.

We modeled every layout below to separate these effects. Each row shows capture split into debris that lands on the sensing face and debris that lands on the side of the tip.
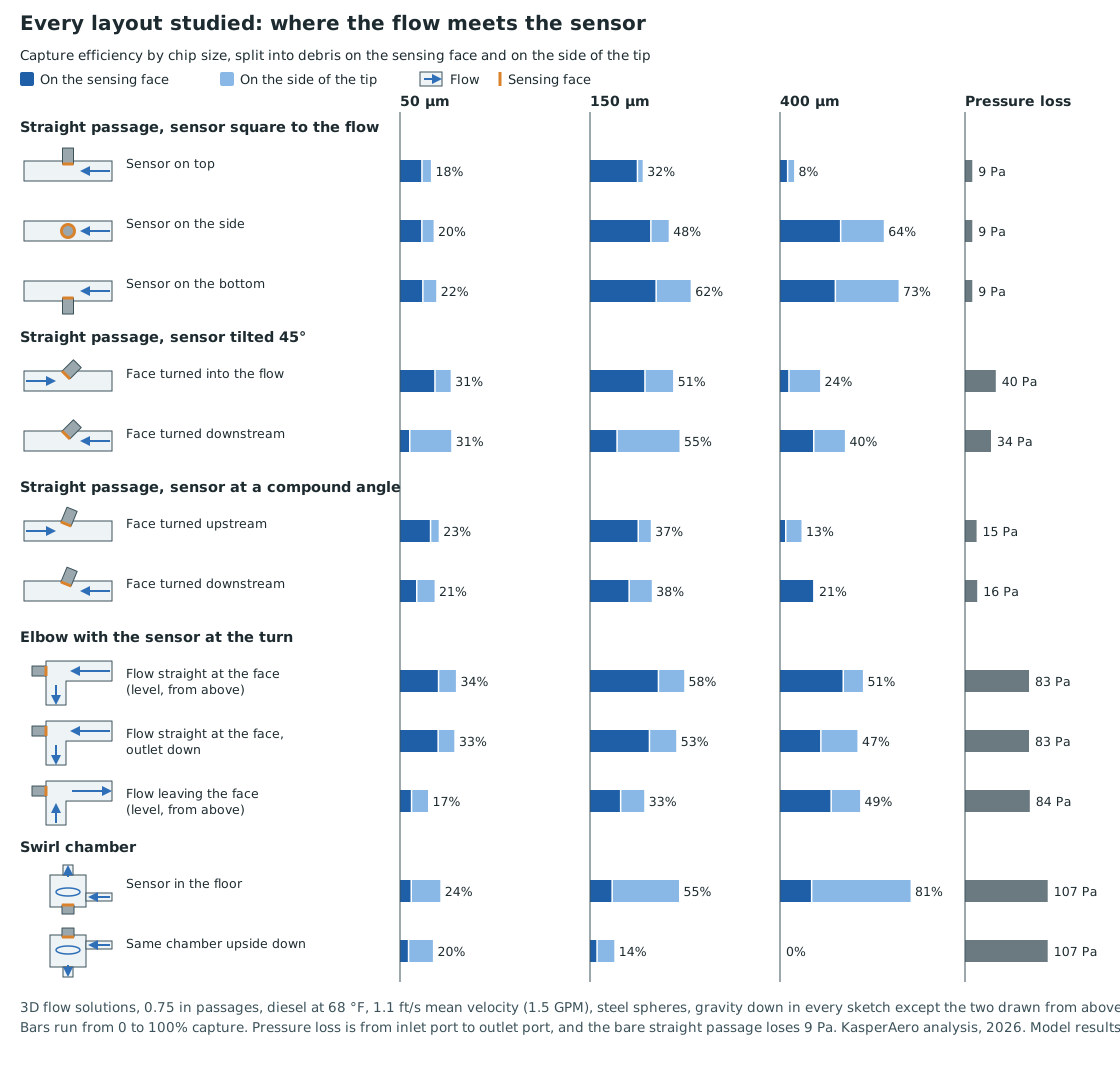
Chart of all twelve layouts with sketches. Straight passage, sensor on top, side and bottom: 18, 20 and 22 percent at 50 microns, 9 Pa. Sensor tilted 45 degrees into the flow or downstream: 31 percent each, 40 and 34 Pa. Compound angle: 23 and 21 percent, 15 Pa. Elbow with the flow straight at the face: 34 and 33 percent, 83 Pa. Elbow with the flow leaving the face: 17 percent, 84 Pa. Swirl chamber, sensor in the floor: 24 percent at 50 microns and 81 percent at 400 microns, 107 Pa. Upside down: 0 percent at 400 microns.
Every layout studied, with capture split between the sensing face (dark) and the side of the tip (light), and the pressure loss. Diesel at 68°F, 1.1 ft/s. The elbows are the clearest test: the same part, the same pressure loss, and only the direction of the flow changed.

The elbow shows the effect of aiming most clearly. With the flow running straight at the face, it caught 34% of 50 µm chips, 24 points of that on the face. With the flow reversed, so that it turns past the face and leaves, the same part caught 17%, only 7 points on the face. The geometry and the pressure loss were identical. Tilting the sensor 45° gives a second example. Turned into the flow or turned downstream, it caught about 31% of small chips either way, but facing into the flow put 21 points on the face against 6.

For large chips, gravity still outweighs inertia at these velocities. The elbow aimed at the face caught 51% of 400 µm chips, below the 73% of a plain passage with the sensor on the bottom. At 2.2 ft/s the elbow's large-chip capture rose to 61% while its small-chip capture fell, which is the inertial effect growing with velocity. The swirl chamber caught the most large chips (81%), but mostly on the side of the tip, at the highest pressure loss of any layout, and none at all when turned over.

Design action. Point the incoming flow at the sensing face. Place the sensor at the outside of a turn, facing the incoming flow, or tilt the face into the flow. Avoid layouts where the flow turns past the face and leaves it. Keep the sensor low as well, since at typical fuel and oil velocities gravity, not inertia, decides where large chips go.

Same part, same pressure loss: aiming the flow at the face doubled small-chip capture and more than tripled the debris landing on the face.

5. Put the Tip into the Flow

Where the sensing face sits relative to the passage wall is the cheapest choice in the installation. We modeled a straight 0.75 in line of MIL-PRF-23699 at 245°F with the NZMS face set back in its port, flush with the wall, and standing up to 0.3 in into the flow.

Line chart of capture efficiency against the position of the sensing face, from 0.15 inch set back to 0.3 inch into the flow, for 50, 150 and 400 micron chips. 50 micron capture rises from 6 percent set back to 15 percent flush and 53 percent at 0.3 inch.
Capture against the position of the sensing face. Every step into the flow adds capture. A face set back in its port catches the least, because the fluid in the port is still and the face sits farther from the moving debris.

Set back 0.15 in, the sensor caught 6% of 50 µm chips and 26% of 150 µm chips. Flush with the wall, it caught 15% and 46%. With the face 0.3 in into the flow, it caught 53% and 93%. Large chips reached 98% once the face stood 0.15 in into the flow. The cross-sections below show why. They mark the part of the pipe whose debris the sensor catches.

Five pipe cross-sections showing the region of the pipe whose 150 micron debris is caught, for the face set back 0.1 inch, flush, and 0.1, 0.2 and 0.3 inch into the flow. The caught region grows from a patch beside the sensor to most of the pipe.
The capture area for 150 µm chips, looking downstream with the sensor on the right wall. A face in the flow draws debris from a much larger part of the pipe than a face set back in its port.

The three-dimensional cases in diesel show the same trend, from 13% of 50 µm chips with the tip flush to 46% at 0.3 in, at a pressure loss of 25 Pa against 8.6 Pa for the bare passage. The chart below puts every layout on one plot of small-chip capture against pressure loss.

Scatter chart of 50 micron capture against pressure loss. The tip sweep on a straight passage climbs from 13 percent at 8.6 Pa to 46 percent at 25 Pa. Other layouts sit lower and to the right: sensor tilted 45 degrees 31 percent at 37 Pa, elbow with flow at the face 34 percent at 83 Pa, swirl chamber 24 percent at 107 Pa.
Small-chip capture against pressure loss for every layout studied. Extending the tip (orange) buys more capture per pascal than any change of sensor angle or passage shape (blue). Diesel at 68°F, 1.1 ft/s.

At this velocity, every layout studied cost less than 0.02 psi. Losses rise quickly once the flow separates, however. The elbow lost 8 Pa at 0.36 ft/s, 83 Pa at 1.1 ft/s and 197 Pa at 2.2 ft/s. In a fast passage, the shape of the passage becomes the larger cost.

A face in the flow must also keep what it catches. The magnet presses a captured chip against the face, and the fluid drags on it. The drag grows with the viscosity of the fluid and with its speed at the chip. The hold of the magnet does not. In hot oil the hold is far larger than the drag, even in a strong surge. Cold, thick oil is the harder case. At a cold start, the drag on a captured chip can be hundreds of times larger than at operating temperature, and fine chips on a face that stands into the flow are the most exposed. A growing pile of debris also stands farther into the flow than a single chip. Our pipe model does not resolve the flow over a protruding face well enough to put a number on this, so it is a check to make for each installation.

Design action. Put the face into the flow rather than setting it back in a port. Every step into the flow added capture in our models, up to 0.3 in in a 0.75 in line. Then check three limits at the extreme conditions: the flow load on the tip, the pressure loss at maximum flow, and whether captured debris stays on the face in the coldest fluid at full flow.

What You Cannot Choose: The Debris

A designer does not choose the steel the debris comes from. That is set by the gears and bearings being monitored. The useful finding is that capture hardly depends on it.

0 ptschange in capture for saturation magnetization from 0.6 to 2.1 T
<1 ptchange in capture for relative permeability from 1,000 down to 100
4–5×stronger magnetization of a thin flake than a sphere of the same length (flake model)

A small steel particle's own demagnetizing field limits how strongly it magnetizes. For a sphere, the effective susceptibility levels off at about 3 for any relative permeability above about 50, which covers every carbon and alloy steel, soft or hardened. Chips are also far from saturation in the millitesla fields where they are caught. Carbon content and heat treatment therefore do not change capture, and an installation designed for one steel works for all of them.

Two properties of the debris do matter. The first is whether it is magnetic at all. Austenitic stainless steels such as 304 and 316 are nearly invisible to a magnetic sensor. The second is shape. A thin flake magnetizes along its length about four to five times more strongly than a sphere, so the flat spall flakes typical of bearing and gear distress are caught more readily than the spheres used in these models. Sphere results are a conservative baseline.

Consistent Capture in Practice

The five considerations reduce to a short checklist for any installation:

ConsiderationMain effectDesign action
Fluid temperatureSmall-chip capture falls as the fluid thickens. Below freezing, MIL-PRF-23699 lets most chips under 150 µm pass.Evaluate capture at the coldest condition where detection is required. Trend at similar temperatures.
Sensor positionLarge chips settle. A sensor on top loses nearly all 400 µm chips.Mount low, close downstream of the debris source.
Velocity at the sensorSlower flow helps small chips until large chips begin to settle.Size the bore or cavity at the sensor. Check minimum and maximum system flow.
Flow direction at the faceFlow aimed at the face doubles small-chip capture and puts the catch on the face.Face the incoming flow, at the outside of a turn or with the face tilted into the flow.
Face positionA face set back in its port catches the least. Each step into the flow adds capture, for the least pressure loss of any change.Put the face into the flow. Check the flow load on the tip, pressure loss at maximum flow and wash-off in the coldest fluid.

Consistency is the common thread. A sensor installed low, in a cavity sized for the right velocity, with the flow aimed at its face and its tip in the flow, and evaluated over its real temperature range, sees a known and stable fraction of the debris. That sensor produces a debris trend whose changes reflect changes in wear.

Model It Before You Build It

Every result in this article comes from KasperAero's magnetic capture analysis tools. We can analyze the capture efficiency of any fluid system, from a straight line to a complex housing. Working from your CAD model, we solve the three-dimensional flow through the passage, including turbulent flow, and track steel debris of each size through it. The analysis reports capture by particle size, where debris lands on the sensor and the pressure loss, across your range of fluids, temperatures, flow rates and mounting attitudes.

This lets you compare sensor locations, cavity sizes, tip lengths and flow directions before any hardware is cut, and choose the installation that captures debris consistently over the whole operating envelope.

Our Magnetic Capture Analysis Tools »
Request a Capture Analysis »

About the Numbers

All results are KasperAero model results, not test data. The sensor is a standard NZMS with a neodymium ring magnet and a 0.437 in sensing face. Debris is modeled as steel spheres, with gravity included and the magnet at fluid temperature. Capture efficiency is flow-weighted: the fraction of debris carried past the sensor that lands on it.

The pipe model tracks particles through laminar flow in a horizontal 0.75 in line of MIL-PRF-23699, with the sensor at the side and its tip 0.1 in into the flow unless noted. In both models, debris that reaches a wall rests or slides along it under the flow, gravity, the magnet and friction, and is caught where it comes to rest on or beside the sensor. The three-dimensional cases are 0.75 in passages, solved with a lattice Boltzmann large-eddy simulation on a 0.25 mm grid, in diesel at 68°F and a mean velocity of 1.1 ft/s (1.5 GPM) unless noted. Pressure loss is from the inlet port to the outlet port.

Back to Knowledge Hub »